Showing posts with label source. Show all posts

Tuesday, March 20, 2007

New POV Renders


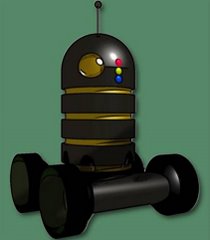
We have completed new files for POVray and now the rings are modeled as single entities that are then assembled into the required stacks. As the image shows the discs can be placed in diffrent patterns so robots can easily be identified by moving the colored discs up and down the stack creating unique patterns for identifacation.
The height of the robot can also be changed easily with this desig by adding or omitting rings. THese parts are modeled to scale and will be used in orthographic view to produce detailed CAD renders for input into milling or molding machines.
The design also allows construction from sheet materail and a suitable cutter like a laser or 2 axis mill cutter (CNC)

Sunday, March 18, 2007

Today we re drew the basic plans on to thick card and cut out the first run templates for the mock up to be assembled this week. The templates are full scale not half as most of the earlier designs were ( this was to make it easier to design in a normal book, while still keeping it all to scale. The top image is the tools we used for this, A compass, some HB pencils sveral rulers of various lengths , and a digital caliper for taking fine measurments of parts we want to fit in later.
The second image is the cut out templates with a ruler for scale ( in inches ) these templates are all that is needed to draw out the parts needed for the robot, At this stage the hardest part is going to be the dome head, this may be revised from the first renders of the robot, And depending on how hard it is to replicate the dome we may release a diffrent head shape for the first run, but we really like this head.
The wheels are gooing to be a little bigger then first thought, but this increases ground clearance.
Later, hackers.
sprocket.